frc robot
- second order swerve kinematics
- full field odometry and localization
- path planning on the fly
- match logging and simulation
- full field odometry and localization
- path planning on the fly
- match logging and simulation
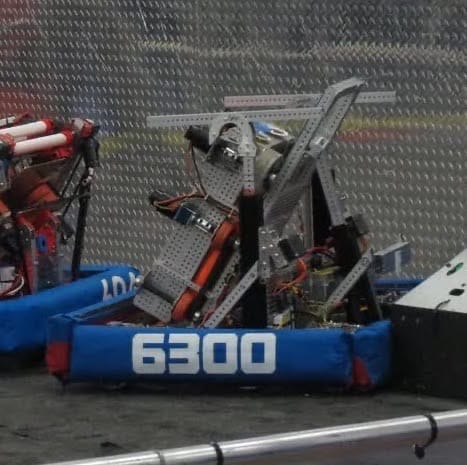
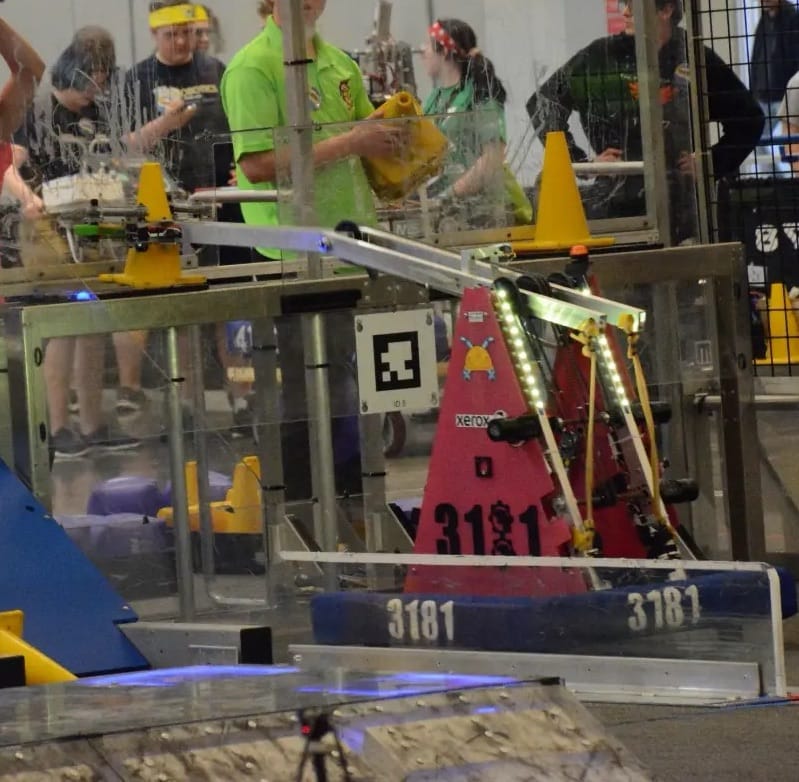
Robot code written in Java for the FIRST Robotics Competition 2022, 2023, and 2024 season. Almost entirely written by me as basically the only programmer on the team.
Some cool things done with the code:
- fully autonomous scoring and pickup
- sensor fusion from 4 camers + wheel odometry for localization
- second order swerve kinematics built off whitepaper
- IK solver for virtual four bar with FF compensation for gravity